Shuttlecock Shooting Robot with Human Positioning Detection Using Raspberry Pi 5 with TensorFlow Lite (TFLite) Inference
Specifications
- Code
- SA2601
- Department
- DKS
- Technology
- Raspberry Pi 5 · TensorFlow
- Theme
- AI & Computer Vision · Education & Society
- Student
- Muhammad Alif Iskandar bin Md Faizal
- Supervisor
- Ja'aris bin Samsudin
Objectives
To detect the position of badminton player on the court using TensorFlow Lite (TFLite). To design a shuttlecock shooting mechanism that can automatically shoot shuttlecock opposing the detected player position. To enable robot to move independently within staying inside defined boundaries using omni-wheel.
Scope of project
The robot is designed for operation in indoor badminton courts only. Navigation is limited to a predefined mapped court environment. TensorFlow Lite Detection only detection.
Project description
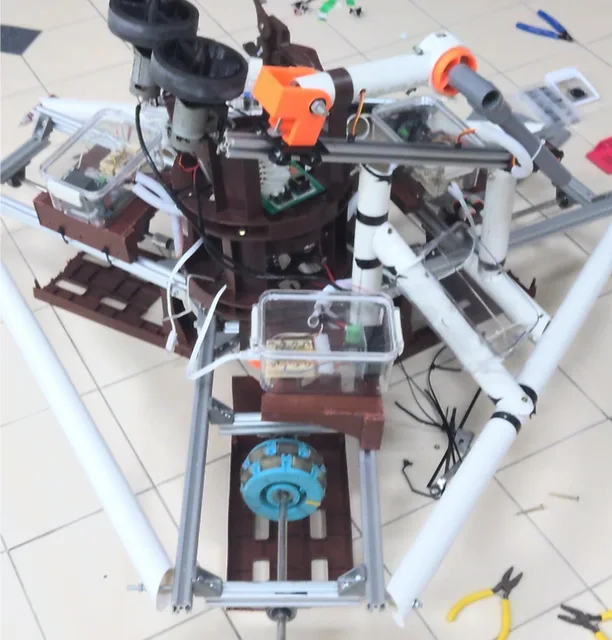
This project develops a shuttlecock shooting robot with human-position detection to support badminton training. A Raspberry Pi 5 processes camera images using TensorFlow Lite to detect a player and determine their position within the camera frame. The robot incorporates a three-wheel omnidirectional platform controlled by an ESP32-S3, while ROS 2 Jazzy provides the framework for communication between its subsystems. A dual counter-rotating flywheel mechanism powered by RS-775 motors launches shuttlecocks, and two servo motors control the feeding mechanism. By combining computer vision, mobile robotics, and automated shuttlecock delivery, the project aims to provide a practical platform for badminton training assistance.