Automatic Emergency Exit Door Obstacle Detection and Removal Robot Using Arduino Mega 2560
Specifications
- Code
- SA2621
- Department
- DKS
- Technology
- Arduino Mega 2560
- Theme
- Safety & Security
- Student
- Muhammad Yazid Zaidan bin Mohd Suhaimi
- Supervisor
- Siti Zaleha binti Abdul Aziz
Objectives
To develop an automatic robot capable of detecting obstacles located behind emergency exit doors using Arduino Mega 2560. To design 12V DC motor-driven mechanism capable of pushing obstacles blocking emergency exit doors. To program an Arduino Mega 2560 to control sensors, motors, and overall robot operation.
Scope of project
The robot detects obstacles behind emergency exit doors using an HC-SR04 ultrasonic sensor. The robot uses a 12V DC worm gear motor to remove obstacles. The worm gear motor is self-locking, so the mechanism stays in position when the motor stops. The robot is designed to push obstacles weighing between 10 kg and 50 kg. The robot is designed for indoor use only, and the HC-SR04 ultrasonic sensor may not detect obstacles accurately in dense smoke.
Project description
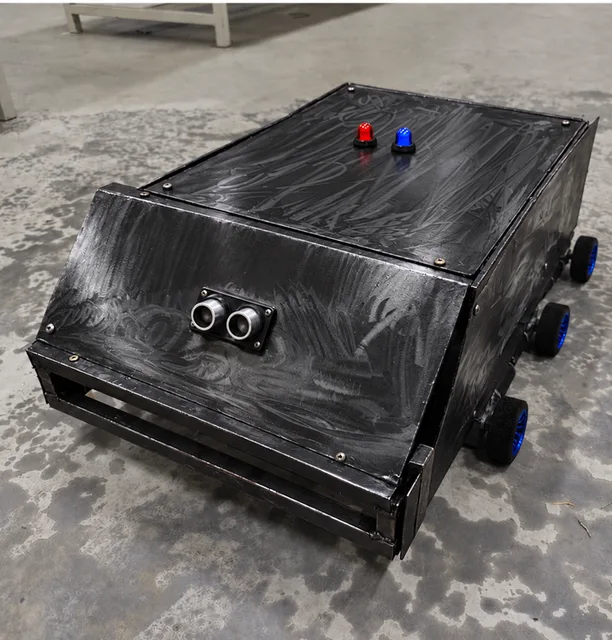
The robot detects movable obstacles behind an emergency exit door and pushes them away from the door area. A front-facing HC-SR04 ultrasonic sensor sends distance readings to an Arduino Mega 2560. The controller drives six worm gear motors through two BTS7960 modules. A timed sequence moves the robot forward, activates the buzzer and reverses towards its starting position. A 12 V 12 Ah lead-acid battery powers the motors. The steel chassis supports the wheels and front push bar. Indoor testing evaluates obstacle detection, pushing displacement, doorway clearance and return position.